CANopen Motor Controller
Real-time, noise-immune BLDC / PMSM motor controllers commanded over the CAN bus — the NESDrive TULPAR series.
On a mobile machine the motor controller never works alone: it talks constantly to the vehicle computer, BMS, display and other drives. CANopen is the industry standard for that conversation. Speed and torque commands travel in real time over a single two-wire line, and current, speed, temperature and fault data are read back over the same line.
In the NESDrive TULPAR series, the TULPAR 100, 150, 250, 275 and 300 offer both CANopen and Modbus, so the same drive fits a CAN-based vehicle architecture as well as a Modbus PLC system. The BAMSI series for brushed DC motors uses Modbus over RS232 as standard; we evaluate brushed DC with CANopen on a project basis.
What CANopen adds to a motor controller
Ratings of CANopen TULPAR models
| Protocol | CANopen · Modbus |
|---|---|
| Physical interface | CAN bus · RS485 · RS232 / USB (by model) |
| Voltage range | 12 – 120 V DC |
| Rated current | 10 – 300 A |
| Motor type | BLDC · PMSM · ACIM |
| Control | FOC / 4Q regenerative |
Where it is used
- AGVs and AMRs with multiple traction motors
- Forklifts with traction, pump and BMS on one bus
- Battery-powered service and transport vehicles
- Multi-axis industrial machinery
TULPAR models with CANopen
| Model | Voltage | Rated current | Peak current | Interface | STO |
|---|---|---|---|---|---|
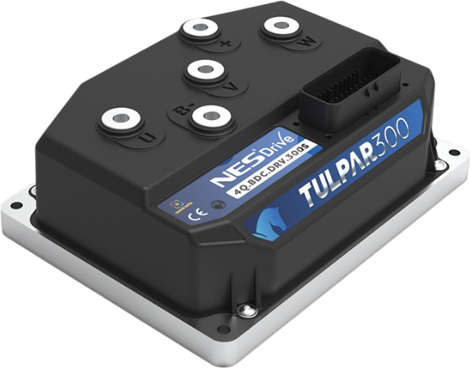
| TULPAR 300 | 12–48 / 48–120 V | 300 A | 450 A | CAN · RS485 · RS232 | Yes |
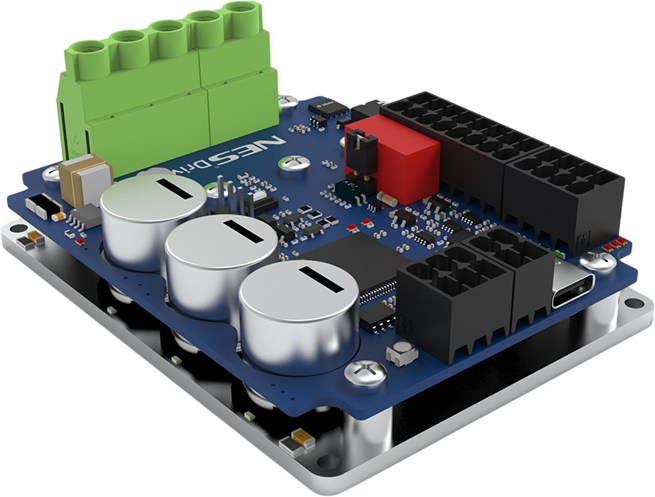
| TULPAR 275 | 12 – 48 V | 75 A | 120 A | CAN · RS485 · RS232 · USB | Yes (isolated) |
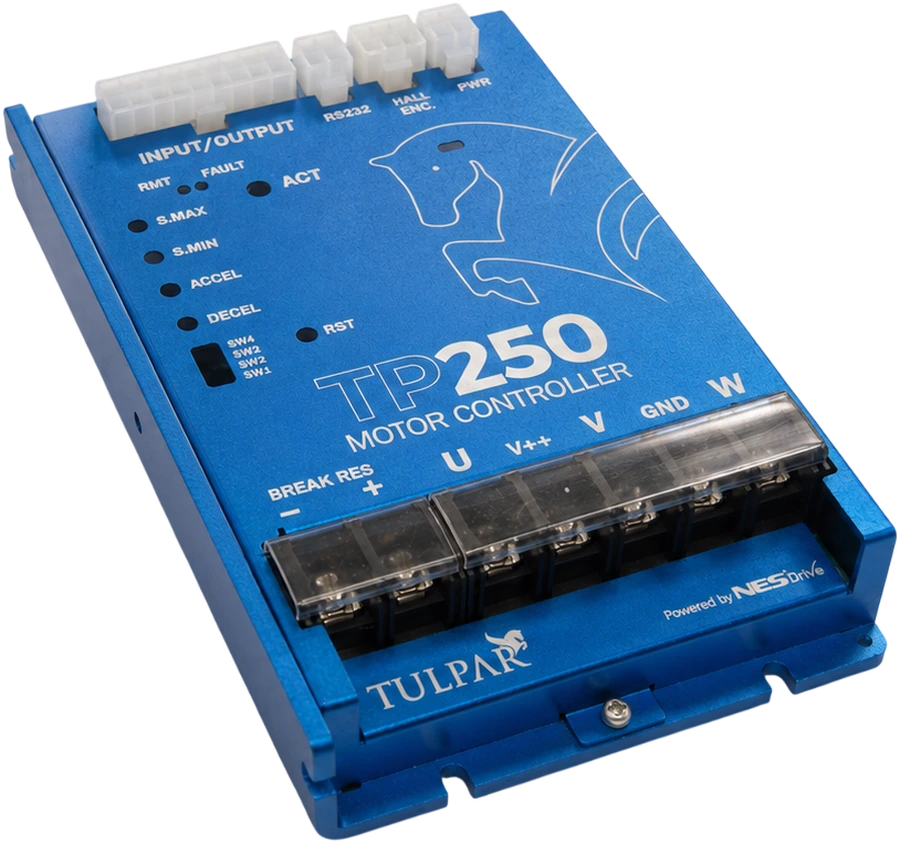
| TULPAR 250 | 12 – 72 V | 50 A | 75 A | CAN · RS485 · RS232 | — |
| TULPAR 150 | 12 – 48 V | 20 A | 60 A | CAN · RS485 · RS232 · USB | Yes (isolated) |
| TULPAR 100 | 12 – 48 V | 10 A | 30 A | CAN · RS485 · USB | Yes (isolated) |
How do I choose a CANopen model?
TULPAR models with CANopen

Frequently asked questions
Which NESDrive drives support CANopen?
TULPAR 100, 150, 250, 275 and 300 support both CANopen and Modbus. TULPAR 200 offers Modbus RTU and RS232 only. The BAMSI series uses Modbus over RS232 (USB TTL on the BAMSI 200).
Can I control a brushed DC motor over CANopen?
The standard communication of the BAMSI series for brushed DC is not CANopen. Because we design the boards ourselves, we evaluate brushed DC with CANopen on a project basis — contact us with your motor ratings and system architecture.
Does the CAN bus need termination resistors?
Yes. Fit one 120 Ω resistor at each physical end of the bus. With the system powered off you should measure about 60 Ω between CAN_H and CAN_L.
Which baud rate should I choose?
All devices on the bus must run at the same speed. The higher the speed, the shorter the allowed length: about 100 m at 500 kbit/s, about 250 m at 250 kbit/s. On short in-vehicle buses, 250 or 500 kbit/s is common.
Should I use CANopen or Modbus?
CANopen suits mobile vehicles, multi-node networks and real-time control; Modbus is more practical for fixed installations and PLC integration. Since CANopen TULPAR models support both, you can change your mind later.
Share your bus layout, host controller and motor ratings; we will recommend the right TULPAR model and communication settings.
Related posts
 Guide
CANopen Motor Control: CAN Bus Wiring and Setup
What is CANopen and how do you connect a motor controller to it? CAN bus wiring, 120 Ω termination, node ID, baud rate, PDO/SDO and common setup mistakes.
 Technical
CANopen or Modbus? Motor Drive Communication Protocols
The difference between CANopen and Modbus communication protocols in motor drives, which to choose for which application, and NESDrive support.